Overview
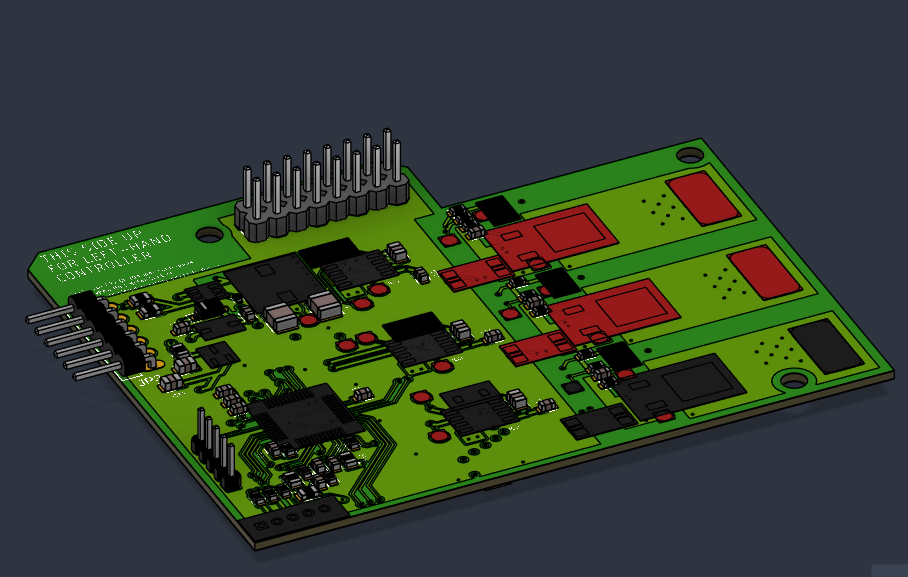
I designed the motor controller for my foldable electric skateboard project, built around a hybrid square-wave/sinusoidal drive to get efficient, torquey performance out of 700W combined power (with two boards). The three-phase stage is driven by a dsPIC33CK32MP105 motor-control DSC with hall-effect sensor feedback, since back-EMF sensing gets unreliable right at the low RPMs where the square-wave mode needs to take over.
Technical materials
What I learned
- Designed a hybrid square-wave/sinusoidal motor drive that switches commutation modes at an RPM threshold - square-wave for low-speed torque, sinusoidal above it for efficiency - currently a hard cutover, with a blended transition planned as a follow-up
- Drove the three-phase motor stage with a dsPIC33CK32MP105 motor-control DSC and hall-effect sensor feedback for commutation, since back-EMF sensing gets unreliable at exactly the low RPMs the square-wave mode is meant to cover